Contact Us

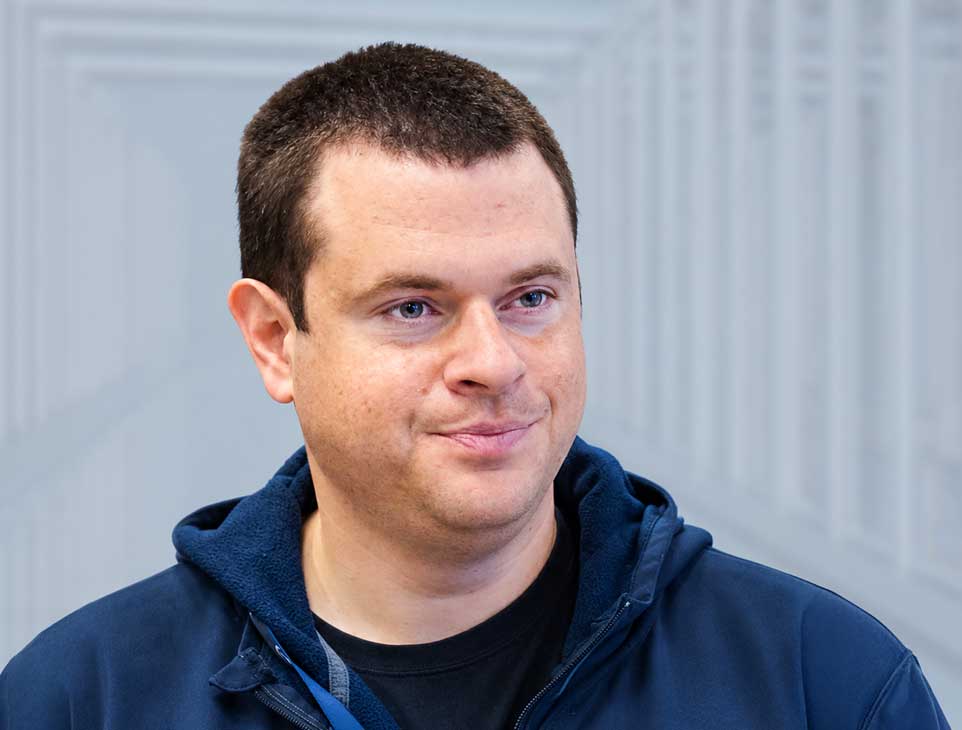
Liraz Mudrik

Visiting Lecturer, Dr.

Biographical Data

B.Sc. (cum laude, Gvahim Excellence Program) and Ph.D. (direct track), both in Aerospace Engineering, Technion, 2018 and 2023, respectively. Navigation algorithms developer at Rafael Advanced Defense Systems, 2015-2018. National Research Council Postdoctoral Research Associate at the Department of Mechanical and Aerospace Engineering, Naval Postgraduate School, Monterey, California, USA, 2024-2026. Visiting Lecturer at the Technion since 2026.

Recipient of the Merhav Prize (2019), the Gutwirth Fellowship for Excellence in Graduate Studies (2019/20), and nine Excellent Teaching Assistant awards in Dynamic Systems and Control Theory (2017/18 to 2021/22).
Main areas of research

His research combines estimation theory, optimization, and optimal control, with application to single- and multi-vehicle aerospace systems. Current interests include:

  • Bayesian estimation and multi-target tracking, including particle filtering and Markov chain Monte Carlo methods
  • Distributed and cooperative estimation for multi-vehicle teams
  • Optimization-based motion planning, including Bernstein-polynomial trajectory parameterizations and observer trajectory optimization for bearing-only localization
  • Control-centric and distributed optimization, including Lyapunov-based algorithm design and prescribed-time generalized Nash equilibrium seeking
  • Stochastic missile guidance, with estimation and guidance unified through Bayesian decision theory

Selected publications

  1. L. Mudrik, I. Kaminer, S. Kragelund, and A. Clark, “Saddle Point Evasion via Curvature-Regularized Gradient Dynamics,” IEEE Control Systems Letters, Vol. 10, pp. 625-630, 2026.
  2. L. Mudrik and Y. Oshman, “Unified Estimation–Guidance Framework Based on Bayesian Decision Theory,” AIAA Journal of Guidance, Control, and Dynamics, Vol. 49, No. 7, pp. 1870-1882, July 2026.
  3. L. Mudrik and Y. Oshman, “Comprehensive Approach to Directly Addressing Estimation Delays in Stochastic Guidance,” AIAA Journal of Guidance, Control, and Dynamics, accepted.
  4. A. Sciacchitano, L. Mudrik, S. Kragelund, and I. Kaminer, “Multi-UAV Trajectory Optimization for Bearing-Only Localization in GPS-Denied Environments,” AIAA Journal of Guidance, Control, and Dynamics, accepted.
  5. L. Mudrik and Y. Oshman, “Bang-Bang Evasion: Its Stochastic Optimality and a Terminal-Set-Based Implementation,” AIAA Journal of Guidance, Control, and Dynamics, accepted.

For a complete and up-to-date list of publications, see Google Scholar: https://scholar.google.com/citations?user=aJxxN3gAAAAJ&hl=en

For more info
Please fill in the details

"*" indicates required fields

This field is for validation purposes and should be left unchanged.
*required fields are marked with an asterisk